#include <cb_spiral.hpp>
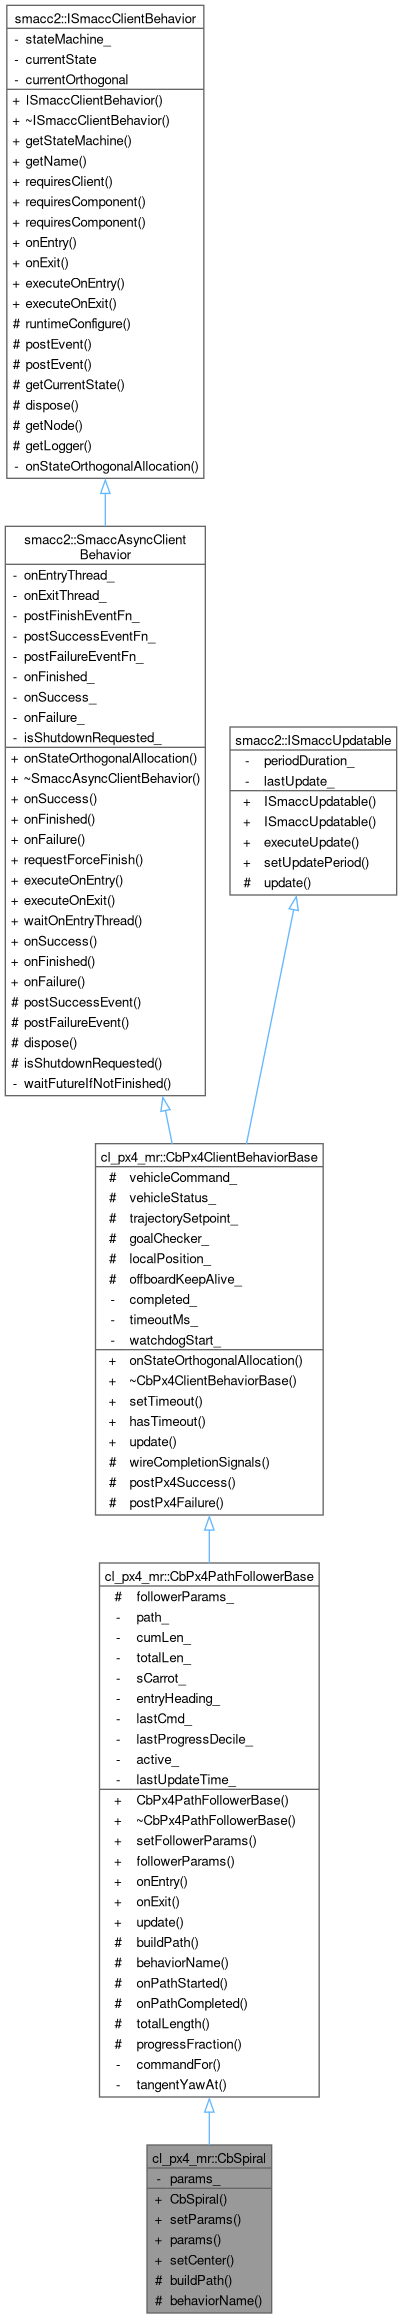
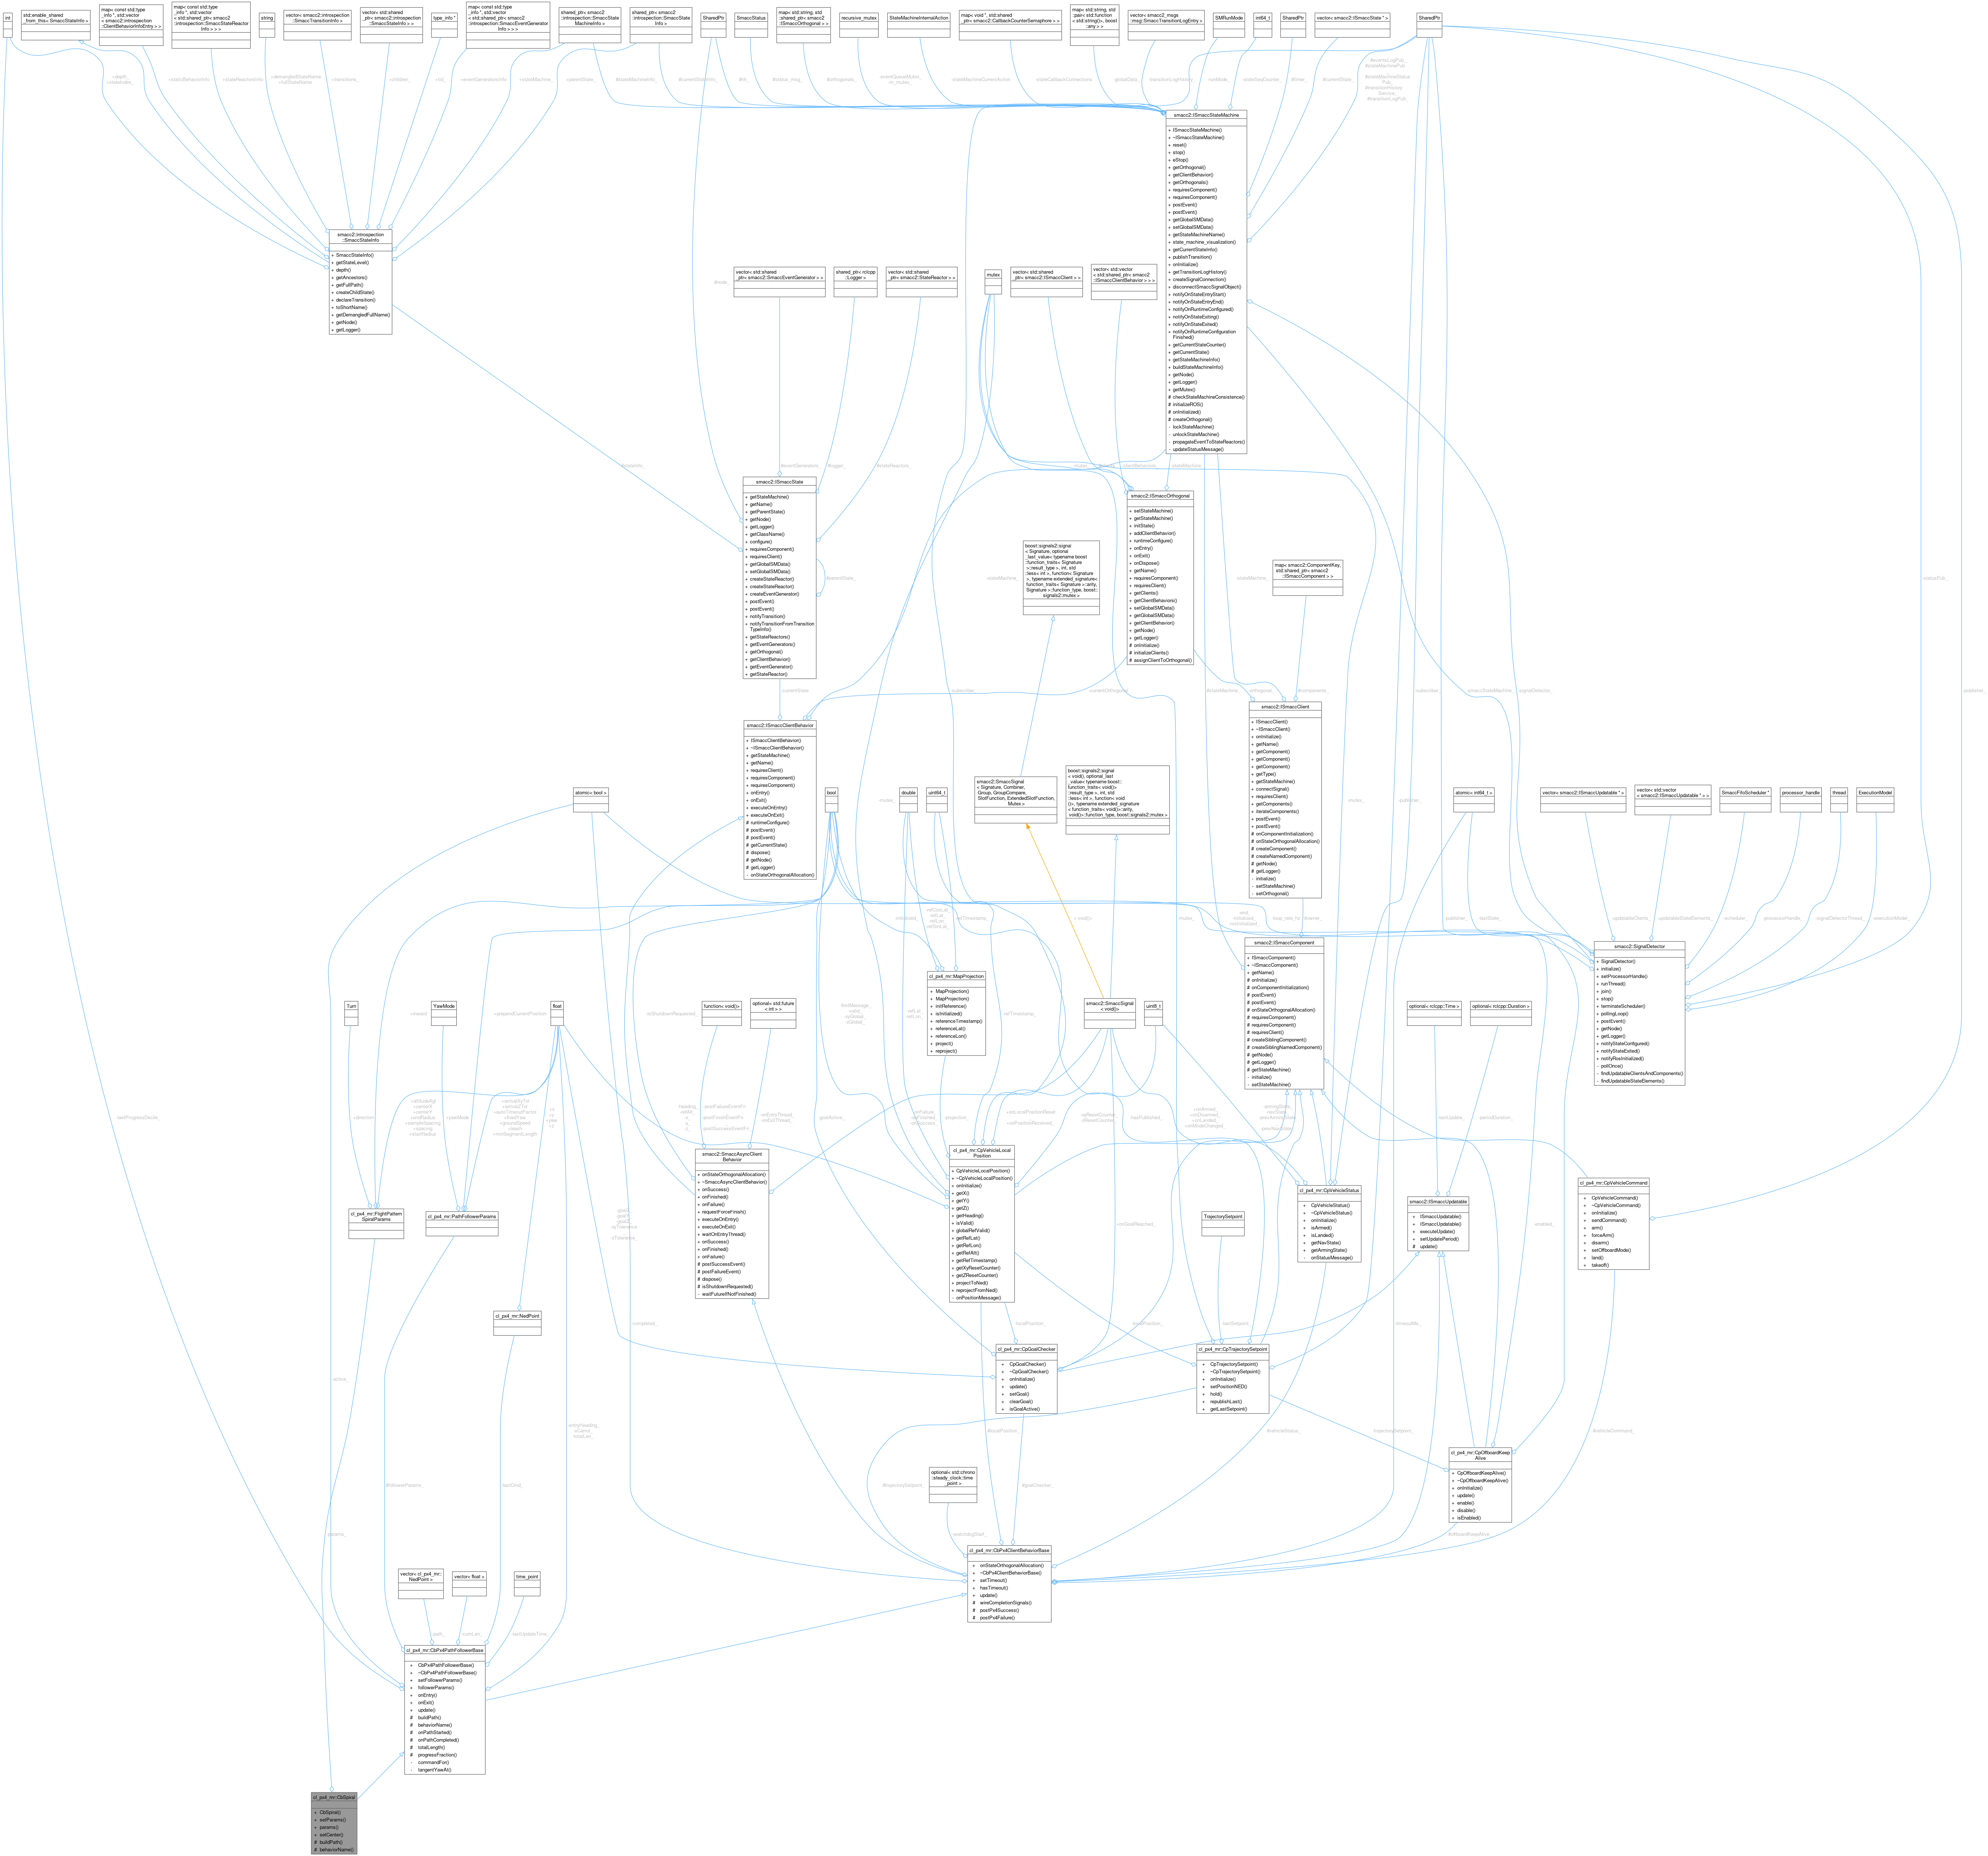
Public Member Functions | |
| CbSpiral (FlightPatternSpiralParams params={}, PathFollowerParams follower={}) | |
| void | setParams (const FlightPatternSpiralParams ¶ms) |
| const FlightPatternSpiralParams & | params () const |
| void | setCenter (float x, float y) |
 Public Member Functions inherited from cl_px4_mr::CbPx4PathFollowerBase | |
| CbPx4PathFollowerBase (PathFollowerParams params={}) | |
| virtual | ~CbPx4PathFollowerBase () |
| void | setFollowerParams (const PathFollowerParams ¶ms) |
| const PathFollowerParams & | followerParams () const |
| void | onEntry () override |
| void | onExit () override |
| void | update () override |
| Public Member Functions inherited from cl_px4_mr::CbPx4ClientBehaviorBase | |
| template<typename TOrthogonal , typename TSourceObject > | |
| void | onStateOrthogonalAllocation () |
| virtual | ~CbPx4ClientBehaviorBase () |
| void | setTimeout (std::chrono::milliseconds timeout) |
| bool | hasTimeout () const |
| Public Member Functions inherited from smacc2::SmaccAsyncClientBehavior | |
| template<typename TOrthogonal , typename TSourceObject > | |
| void | onStateOrthogonalAllocation () |
| virtual | ~SmaccAsyncClientBehavior () |
| template<typename TCallback , typename T > | |
| smacc2::SmaccSignalConnection | onSuccess (TCallback callback, T *object) |
| template<typename TCallback , typename T > | |
| smacc2::SmaccSignalConnection | onFinished (TCallback callback, T *object) |
| template<typename TCallback , typename T > | |
| smacc2::SmaccSignalConnection | onFailure (TCallback callback, T *object) |
| void | requestForceFinish () |
| void | executeOnEntry () override |
| void | executeOnExit () override |
| void | waitOnEntryThread (bool requestFinish) |
| template<typename TCallbackMethod , typename T > | |
| smacc2::SmaccSignalConnection | onSuccess (TCallbackMethod callback, T *object) |
| template<typename TCallbackMethod , typename T > | |
| smacc2::SmaccSignalConnection | onFinished (TCallbackMethod callback, T *object) |
| template<typename TCallbackMethod , typename T > | |
| smacc2::SmaccSignalConnection | onFailure (TCallbackMethod callback, T *object) |
| Public Member Functions inherited from smacc2::ISmaccClientBehavior | |
| ISmaccClientBehavior () | |
| virtual | ~ISmaccClientBehavior () |
| ISmaccStateMachine * | getStateMachine () |
| std::string | getName () const |
| template<typename SmaccClientType > | |
| void | requiresClient (SmaccClientType *&storage) |
| template<typename SmaccComponentType > | |
| void | requiresComponent (SmaccComponentType *&storage, ComponentRequirement requirementType=ComponentRequirement::SOFT) |
| template<typename SmaccComponentType > | |
| void | requiresComponent (std::string name, SmaccComponentType *&storage, ComponentRequirement requirementType=ComponentRequirement::SOFT) |
| Public Member Functions inherited from smacc2::ISmaccUpdatable | |
| ISmaccUpdatable () | |
| ISmaccUpdatable (rclcpp::Duration duration) | |
| void | executeUpdate (rclcpp::Node::SharedPtr node) |
| void | setUpdatePeriod (rclcpp::Duration duration) |
Protected Member Functions | |
| std::vector< NedPoint > | buildPath (const NedPoint ¤t) override |
| const char * | behaviorName () const override |
| Protected Member Functions inherited from cl_px4_mr::CbPx4PathFollowerBase | |
| virtual void | onPathStarted (const std::vector< NedPoint > &) |
| virtual void | onPathCompleted () |
| float | totalLength () const |
| float | progressFraction () const |
| Protected Member Functions inherited from cl_px4_mr::CbPx4ClientBehaviorBase | |
| virtual void | wireCompletionSignals () |
| void | postPx4Success () |
| void | postPx4Failure () |
| Protected Member Functions inherited from smacc2::SmaccAsyncClientBehavior | |
| void | postSuccessEvent () |
| void | postFailureEvent () |
| virtual void | dispose () override |
| bool | isShutdownRequested () |
| onEntry is executed in a new thread. However the current state cannot be left until the onEntry thread finishes. This flag can be checked from the onEntry thread to force finishing the thread. | |
| Protected Member Functions inherited from smacc2::ISmaccClientBehavior | |
| virtual void | runtimeConfigure () |
| template<typename EventType > | |
| void | postEvent (const EventType &ev) |
| template<typename EventType > | |
| void | postEvent () |
| ISmaccState * | getCurrentState () |
| virtual rclcpp::Node::SharedPtr | getNode () const |
| virtual rclcpp::Logger | getLogger () const |
| Protected Member Functions inherited from smacc2::ISmaccUpdatable | |
Private Attributes | |
| FlightPatternSpiralParams | params_ |
Additional Inherited Members | |
| Protected Attributes inherited from cl_px4_mr::CbPx4PathFollowerBase | |
| PathFollowerParams | followerParams_ |
| Protected Attributes inherited from cl_px4_mr::CbPx4ClientBehaviorBase | |
| CpVehicleCommand * | vehicleCommand_ = nullptr |
| CpVehicleStatus * | vehicleStatus_ = nullptr |
| CpTrajectorySetpoint * | trajectorySetpoint_ = nullptr |
| CpGoalChecker * | goalChecker_ = nullptr |
| CpVehicleLocalPosition * | localPosition_ = nullptr |
| CpOffboardKeepAlive * | offboardKeepAlive_ = nullptr |
Detailed Description
Definition at line 33 of file cb_spiral.hpp.
Constructor & Destructor Documentation
◆ CbSpiral()
|
explicit |
Definition at line 26 of file cb_spiral.cpp.
Member Function Documentation
◆ behaviorName()
|
inlineoverrideprotectedvirtual |
Reimplemented from cl_px4_mr::CbPx4PathFollowerBase.
Definition at line 48 of file cb_spiral.hpp.
◆ buildPath()
|
overrideprotectedvirtual |
Implements cl_px4_mr::CbPx4PathFollowerBase.
Definition at line 31 of file cb_spiral.cpp.
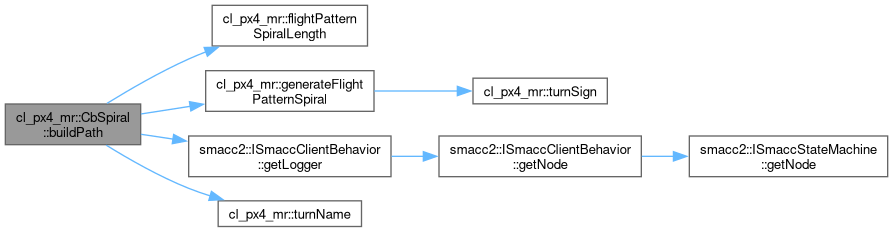
References cl_px4_mr::FlightPatternSpiralParams::centerX, cl_px4_mr::FlightPatternSpiralParams::centerY, cl_px4_mr::FlightPatternSpiralParams::direction, cl_px4_mr::FlightPatternSpiralParams::endRadius, cl_px4_mr::flightPatternSpiralLength(), cl_px4_mr::CbPx4PathFollowerBase::followerParams_, cl_px4_mr::generateFlightPatternSpiral(), smacc2::ISmaccClientBehavior::getLogger(), cl_px4_mr::FlightPatternSpiralParams::inward, params_, cl_px4_mr::FlightPatternSpiralParams::spacing, cl_px4_mr::FlightPatternSpiralParams::startRadius, cl_px4_mr::TANGENT, cl_px4_mr::turnName(), cl_px4_mr::NedPoint::x, cl_px4_mr::NedPoint::y, and cl_px4_mr::PathFollowerParams::yawMode.
◆ params()
|
inline |
Definition at line 39 of file cb_spiral.hpp.
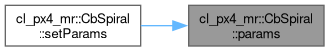
References params_.
Referenced by setParams().
◆ setCenter()
|
inline |
Definition at line 40 of file cb_spiral.hpp.
References cl_px4_mr::FlightPatternSpiralParams::centerX, cl_px4_mr::FlightPatternSpiralParams::centerY, and params_.
◆ setParams()
|
inline |
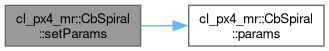
Member Data Documentation
◆ params_
|
private |
Definition at line 51 of file cb_spiral.hpp.
Referenced by buildPath(), params(), setCenter(), and setParams().
The documentation for this class was generated from the following files:
- smacc2_client_library/cl_px4_mr/include/cl_px4_mr/client_behaviors/cb_spiral.hpp
- smacc2_client_library/cl_px4_mr/src/cl_px4_mr/client_behaviors/cb_spiral.cpp
Generated by
 1.12.0