#include <cb_px4_path_follower_base.hpp>
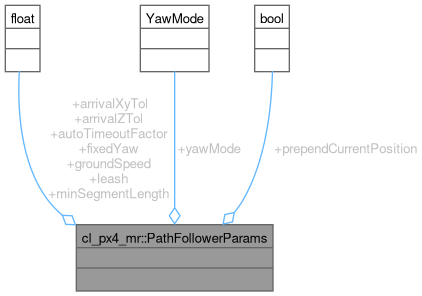
Public Attributes | |
| float | groundSpeed = 3.0f |
| float | leash = 6.0f |
| float | arrivalXyTol = 1.0f |
| float | arrivalZTol = 0.5f |
| YawMode | yawMode = YawMode::TANGENT |
| float | fixedYaw = std::numeric_limits<float>::quiet_NaN() |
| bool | prependCurrentPosition = true |
| float | minSegmentLength = 0.05f |
| float | autoTimeoutFactor = 2.5f |
Detailed Description
Definition at line 42 of file cb_px4_path_follower_base.hpp.
Member Data Documentation
◆ arrivalXyTol
| float cl_px4_mr::PathFollowerParams::arrivalXyTol = 1.0f |
Definition at line 50 of file cb_px4_path_follower_base.hpp.
Referenced by cl_px4_mr::CbPx4PathFollowerBase::update().
◆ arrivalZTol
| float cl_px4_mr::PathFollowerParams::arrivalZTol = 0.5f |
Definition at line 51 of file cb_px4_path_follower_base.hpp.
Referenced by cl_px4_mr::CbAscendToAltitude::buildPath(), and cl_px4_mr::CbPx4PathFollowerBase::update().
◆ autoTimeoutFactor
| float cl_px4_mr::PathFollowerParams::autoTimeoutFactor = 2.5f |
Definition at line 58 of file cb_px4_path_follower_base.hpp.
Referenced by cl_px4_mr::CbPx4PathFollowerBase::onEntry().
◆ fixedYaw
| float cl_px4_mr::PathFollowerParams::fixedYaw = std::numeric_limits<float>::quiet_NaN() |
Definition at line 53 of file cb_px4_path_follower_base.hpp.
Referenced by cl_px4_mr::CbSineWaveHorizontal::buildPath(), and cl_px4_mr::CbPx4PathFollowerBase::commandFor().
◆ groundSpeed
| float cl_px4_mr::PathFollowerParams::groundSpeed = 3.0f |
Definition at line 44 of file cb_px4_path_follower_base.hpp.
Referenced by cl_px4_mr::CbAscendToAltitude::buildPath(), cl_px4_mr::CbSineWaveVertical::buildPath(), cl_px4_mr::CbPx4PathFollowerBase::onEntry(), and cl_px4_mr::CbPx4PathFollowerBase::update().
◆ leash
| float cl_px4_mr::PathFollowerParams::leash = 6.0f |
Definition at line 49 of file cb_px4_path_follower_base.hpp.
Referenced by cl_px4_mr::CbAscendToAltitude::buildPath(), cl_px4_mr::CbPx4PathFollowerBase::onEntry(), and cl_px4_mr::CbPx4PathFollowerBase::update().
◆ minSegmentLength
| float cl_px4_mr::PathFollowerParams::minSegmentLength = 0.05f |
Definition at line 55 of file cb_px4_path_follower_base.hpp.
Referenced by cl_px4_mr::CbPx4PathFollowerBase::onEntry().
◆ prependCurrentPosition
| bool cl_px4_mr::PathFollowerParams::prependCurrentPosition = true |
Definition at line 54 of file cb_px4_path_follower_base.hpp.
Referenced by cl_px4_mr::CbAscendToAltitude::buildPath(), cl_px4_mr::CbSineWaveHorizontal::buildPath(), cl_px4_mr::CbSineWaveVertical::buildPath(), and cl_px4_mr::CbPx4PathFollowerBase::onEntry().
◆ yawMode
| YawMode cl_px4_mr::PathFollowerParams::yawMode = YawMode::TANGENT |
Definition at line 52 of file cb_px4_path_follower_base.hpp.
Referenced by cl_px4_mr::CbAscendToAltitude::buildPath(), cl_px4_mr::CbGridPattern::buildPath(), cl_px4_mr::CbLawnmower::buildPath(), cl_px4_mr::CbLoiter::buildPath(), cl_px4_mr::CbSineWaveHorizontal::buildPath(), cl_px4_mr::CbSineWaveVertical::buildPath(), cl_px4_mr::CbSpiral::buildPath(), cl_px4_mr::CbSquareSpiral::buildPath(), cl_px4_mr::CbVSSearch::buildPath(), and cl_px4_mr::CbPx4PathFollowerBase::commandFor().
The documentation for this struct was generated from the following file:
- smacc2_client_library/cl_px4_mr/include/cl_px4_mr/client_behaviors/cb_px4_path_follower_base.hpp
Generated by
 1.12.0