#include <geo_utils.hpp>
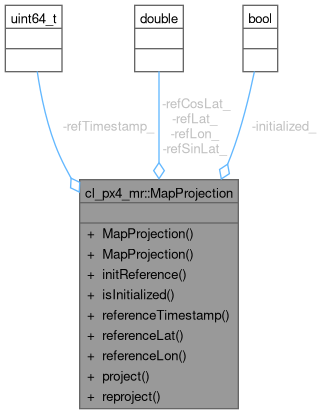
Public Member Functions | |
| MapProjection ()=default | |
| MapProjection (double lat0, double lon0, uint64_t timestamp=0) | |
| void | initReference (double lat0, double lon0, uint64_t timestamp=0) |
| bool | isInitialized () const |
| uint64_t | referenceTimestamp () const |
| double | referenceLat () const |
| double | referenceLon () const |
| void | project (double lat, double lon, float &x, float &y) const |
| void | reproject (float x, float y, double &lat, double &lon) const |
Private Attributes | |
| uint64_t | refTimestamp_ = 0 |
| double | refLat_ = 0.0 |
| double | refLon_ = 0.0 |
| double | refSinLat_ = 0.0 |
| double | refCosLat_ = 1.0 |
| bool | initialized_ = false |
Detailed Description
Definition at line 69 of file geo_utils.hpp.
Constructor & Destructor Documentation
◆ MapProjection() [1/2]
|
default |
◆ MapProjection() [2/2]
|
inline |
Definition at line 74 of file geo_utils.hpp.
References initReference().

Member Function Documentation
◆ initReference()
|
inline |
Definition at line 79 of file geo_utils.hpp.
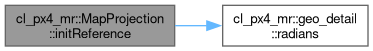
References initialized_, cl_px4_mr::geo_detail::radians(), refCosLat_, refLat_, refLon_, refSinLat_, and refTimestamp_.
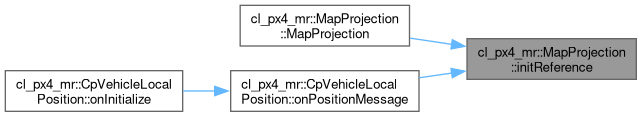
Referenced by MapProjection(), and cl_px4_mr::CpVehicleLocalPosition::onPositionMessage().
◆ isInitialized()
|
inline |
Definition at line 89 of file geo_utils.hpp.
References initialized_.
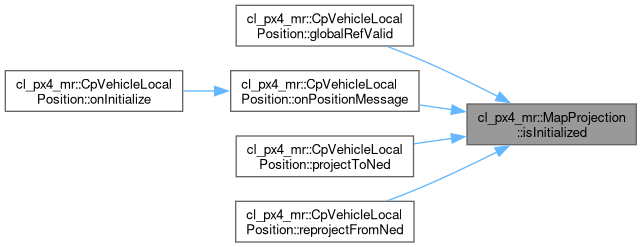
Referenced by cl_px4_mr::CpVehicleLocalPosition::globalRefValid(), cl_px4_mr::CpVehicleLocalPosition::onPositionMessage(), cl_px4_mr::CpVehicleLocalPosition::projectToNed(), and cl_px4_mr::CpVehicleLocalPosition::reprojectFromNed().
◆ project()
|
inline |
Definition at line 95 of file geo_utils.hpp.
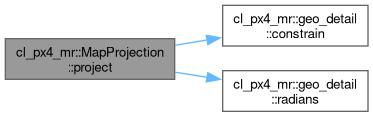
References cl_px4_mr::geo_detail::constrain(), cl_px4_mr::kEarthRadiusM, cl_px4_mr::geo_detail::radians(), refCosLat_, refLon_, and refSinLat_.
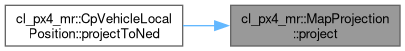
Referenced by cl_px4_mr::CpVehicleLocalPosition::projectToNed().
◆ referenceLat()
|
inline |
Definition at line 91 of file geo_utils.hpp.
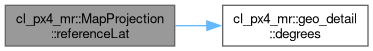
References cl_px4_mr::geo_detail::degrees(), and refLat_.
◆ referenceLon()
|
inline |
Definition at line 92 of file geo_utils.hpp.
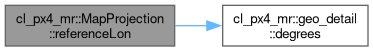
References cl_px4_mr::geo_detail::degrees(), and refLon_.
◆ referenceTimestamp()
|
inline |
◆ reproject()
|
inline |
Definition at line 120 of file geo_utils.hpp.
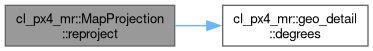
References cl_px4_mr::geo_detail::degrees(), cl_px4_mr::kEarthRadiusM, refCosLat_, refLat_, refLon_, and refSinLat_.
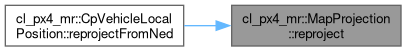
Referenced by cl_px4_mr::CpVehicleLocalPosition::reprojectFromNed().
Member Data Documentation
◆ initialized_
|
private |
Definition at line 151 of file geo_utils.hpp.
Referenced by initReference(), and isInitialized().
◆ refCosLat_
|
private |
Definition at line 150 of file geo_utils.hpp.
Referenced by initReference(), project(), and reproject().
◆ refLat_
|
private |
Definition at line 147 of file geo_utils.hpp.
Referenced by initReference(), referenceLat(), and reproject().
◆ refLon_
|
private |
Definition at line 148 of file geo_utils.hpp.
Referenced by initReference(), project(), referenceLon(), and reproject().
◆ refSinLat_
|
private |
Definition at line 149 of file geo_utils.hpp.
Referenced by initReference(), project(), and reproject().
◆ refTimestamp_
|
private |
Definition at line 146 of file geo_utils.hpp.
Referenced by initReference(), and referenceTimestamp().
The documentation for this class was generated from the following file:
- smacc2_client_library/cl_px4_mr/include/cl_px4_mr/utils/geo_utils.hpp
Generated by
 1.12.0