cb_px4_path_follower_base.hpp File Reference
#include <cl_px4_mr/client_behaviors/cb_px4_client_behavior_base.hpp>#include <cl_px4_mr/utils/geo_utils.hpp>#include <atomic>#include <chrono>#include <limits>#include <vector>
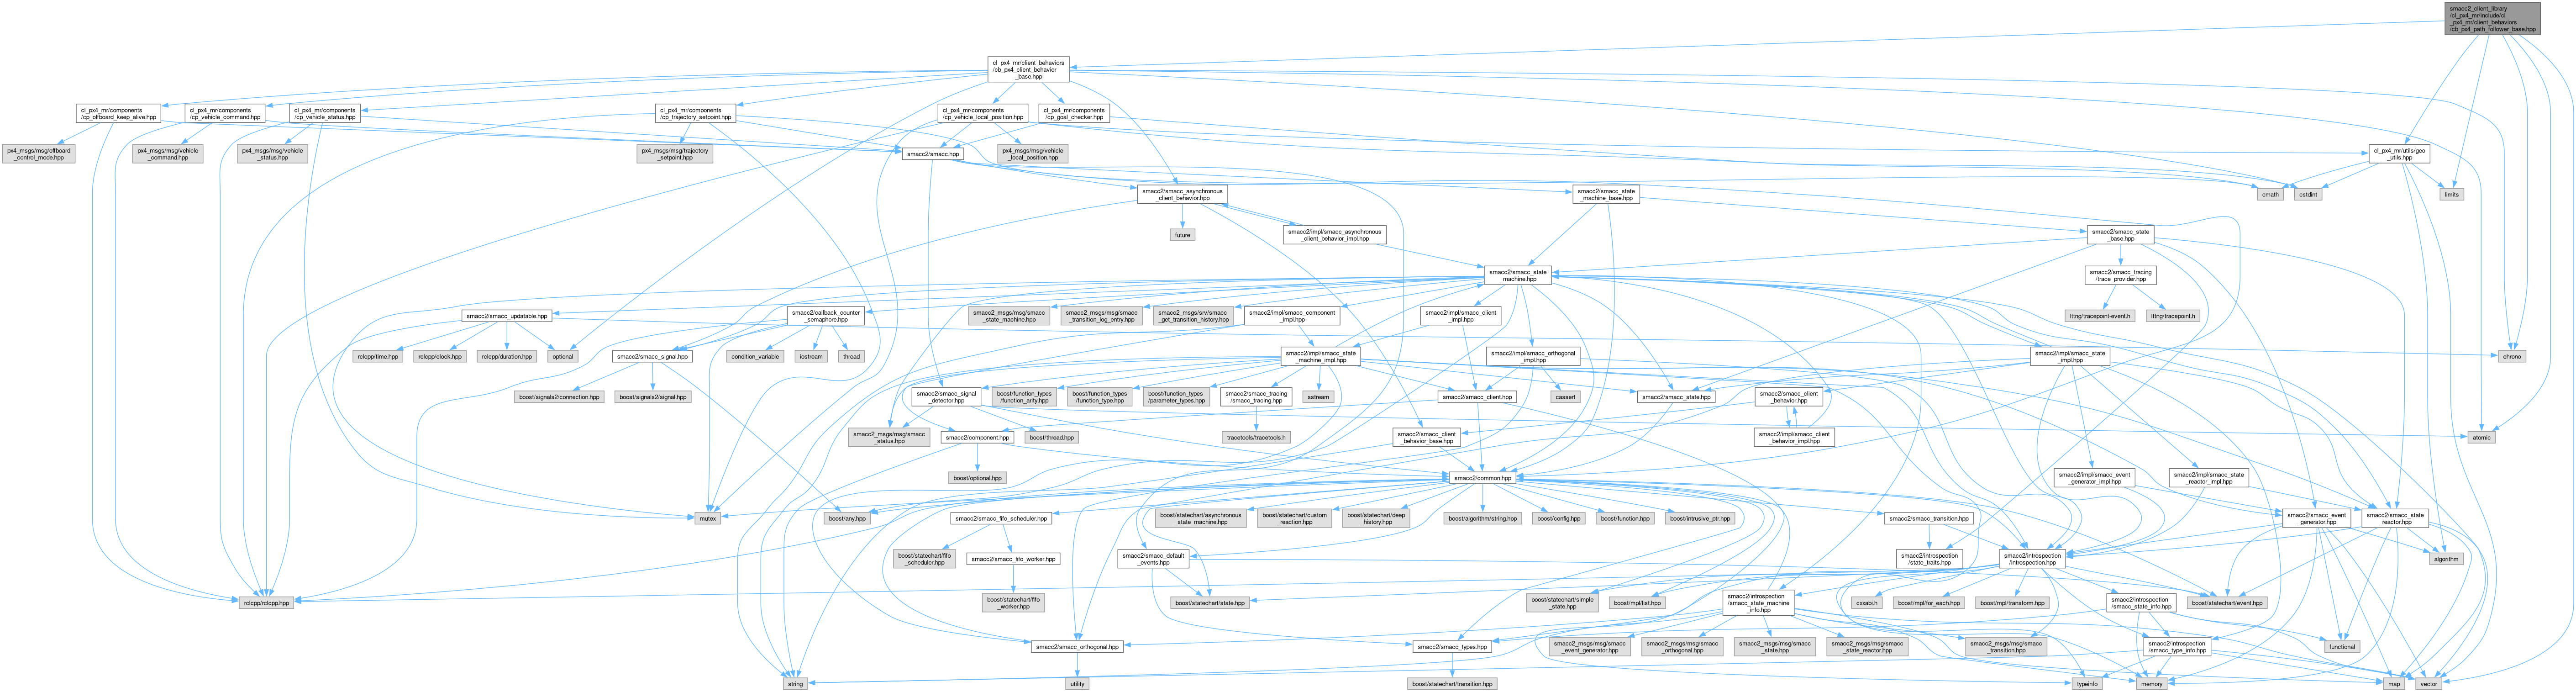
Include dependency graph for cb_px4_path_follower_base.hpp:
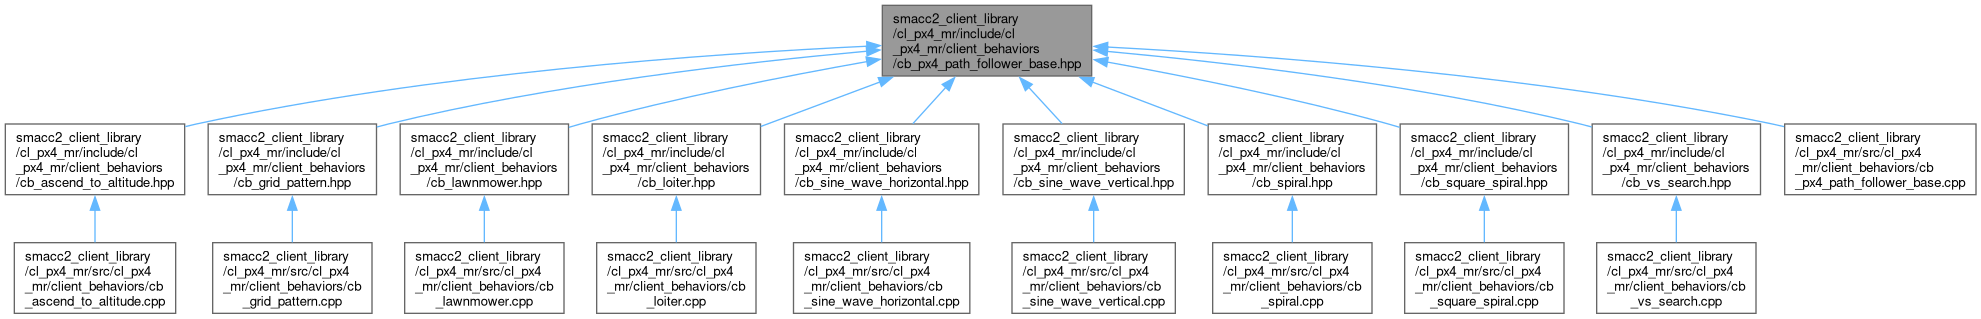
This graph shows which files directly or indirectly include this file:
Go to the source code of this file.
Classes | |
| struct | cl_px4_mr::PathFollowerParams |
| class | cl_px4_mr::CbPx4PathFollowerBase |
Namespaces | |
| namespace | cl_px4_mr |
Enumerations | |
| enum class | cl_px4_mr::YawMode { cl_px4_mr::TANGENT , cl_px4_mr::FIXED , cl_px4_mr::PER_VERTEX , cl_px4_mr::HOLD_ENTRY } |
Generated by
 1.12.0