cp_forward_obstacle_guard.cpp File Reference
#include <cl_px4_mr/components/cp_forward_obstacle_guard.hpp>#include <tf2/LinearMath/Matrix3x3.h>#include <tf2/LinearMath/Quaternion.h>#include <sensor_msgs/point_cloud2_iterator.hpp>#include <limits>
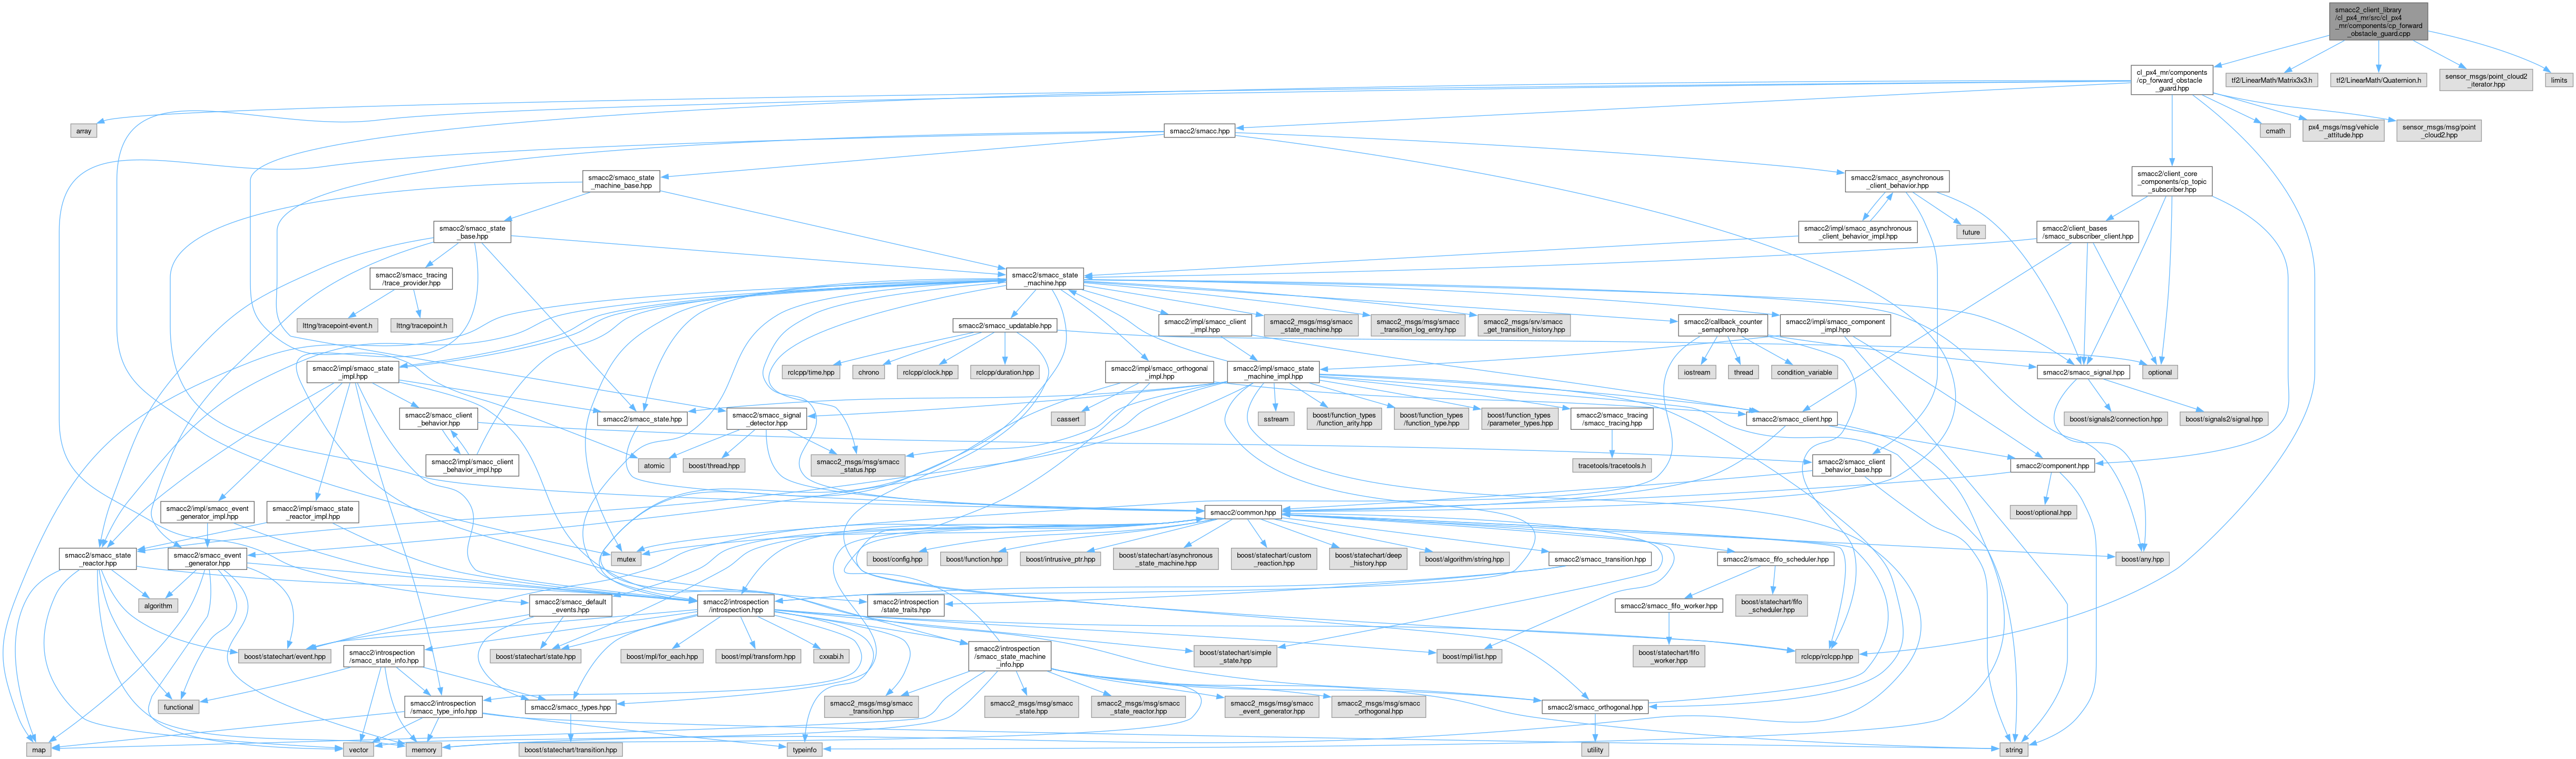
Include dependency graph for cp_forward_obstacle_guard.cpp:
Go to the source code of this file.
Namespaces | |
| namespace | cl_px4_mr |
Generated by
 1.12.0